Document —
PressRelease_Carmenta-ROSintegration_20Oct2026.pdf
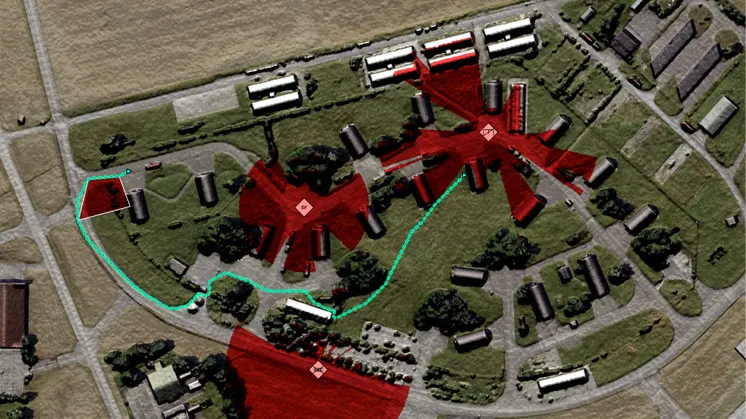
Carmenta today announced a new integration between Carmenta Terrain Router and ROS (Robot Operating System), enabling
uncrewed ground vehicles (UGVs) to recalculate routes onboard during missions. The integration helps autonomous vehicles adapt to changing conditions, helping improve mobility and enhance survivability in contested environments.
go to media item
- License:
- Media Use
The content may be downloaded by journalists, bloggers, columnists, creators of public opinion, etc. It can be used and shared in different media channels to convey, narrate, and comment on your press releases, posts, or information, provided that the content is unmodified. The author or creator shall be attributed to the extent and in the manner required by good practice (this means, for example, that photographers should be attributed).
- File format: